OpenMANIPULATOR-X (RM-X52-TNM)
ROBOTIS · South Korea · Seoul · active
Plates · credit and license on each
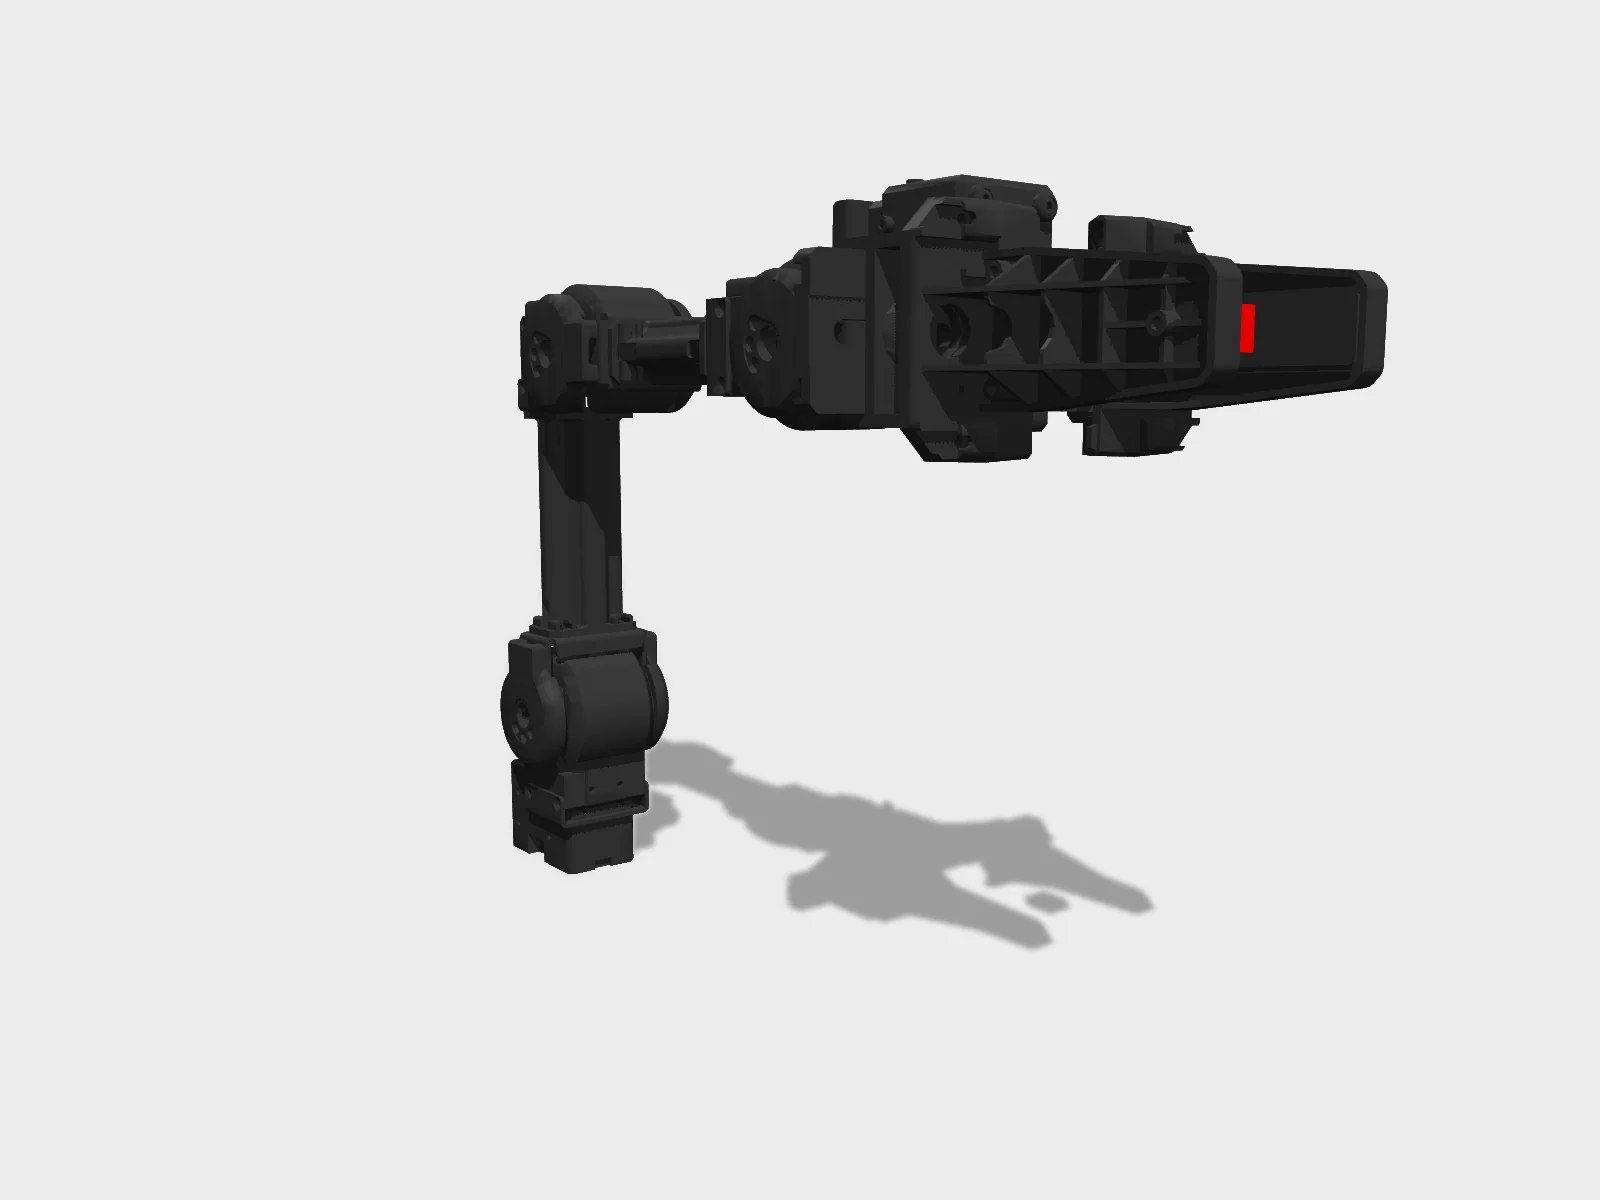
Studio render of the published URDF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source 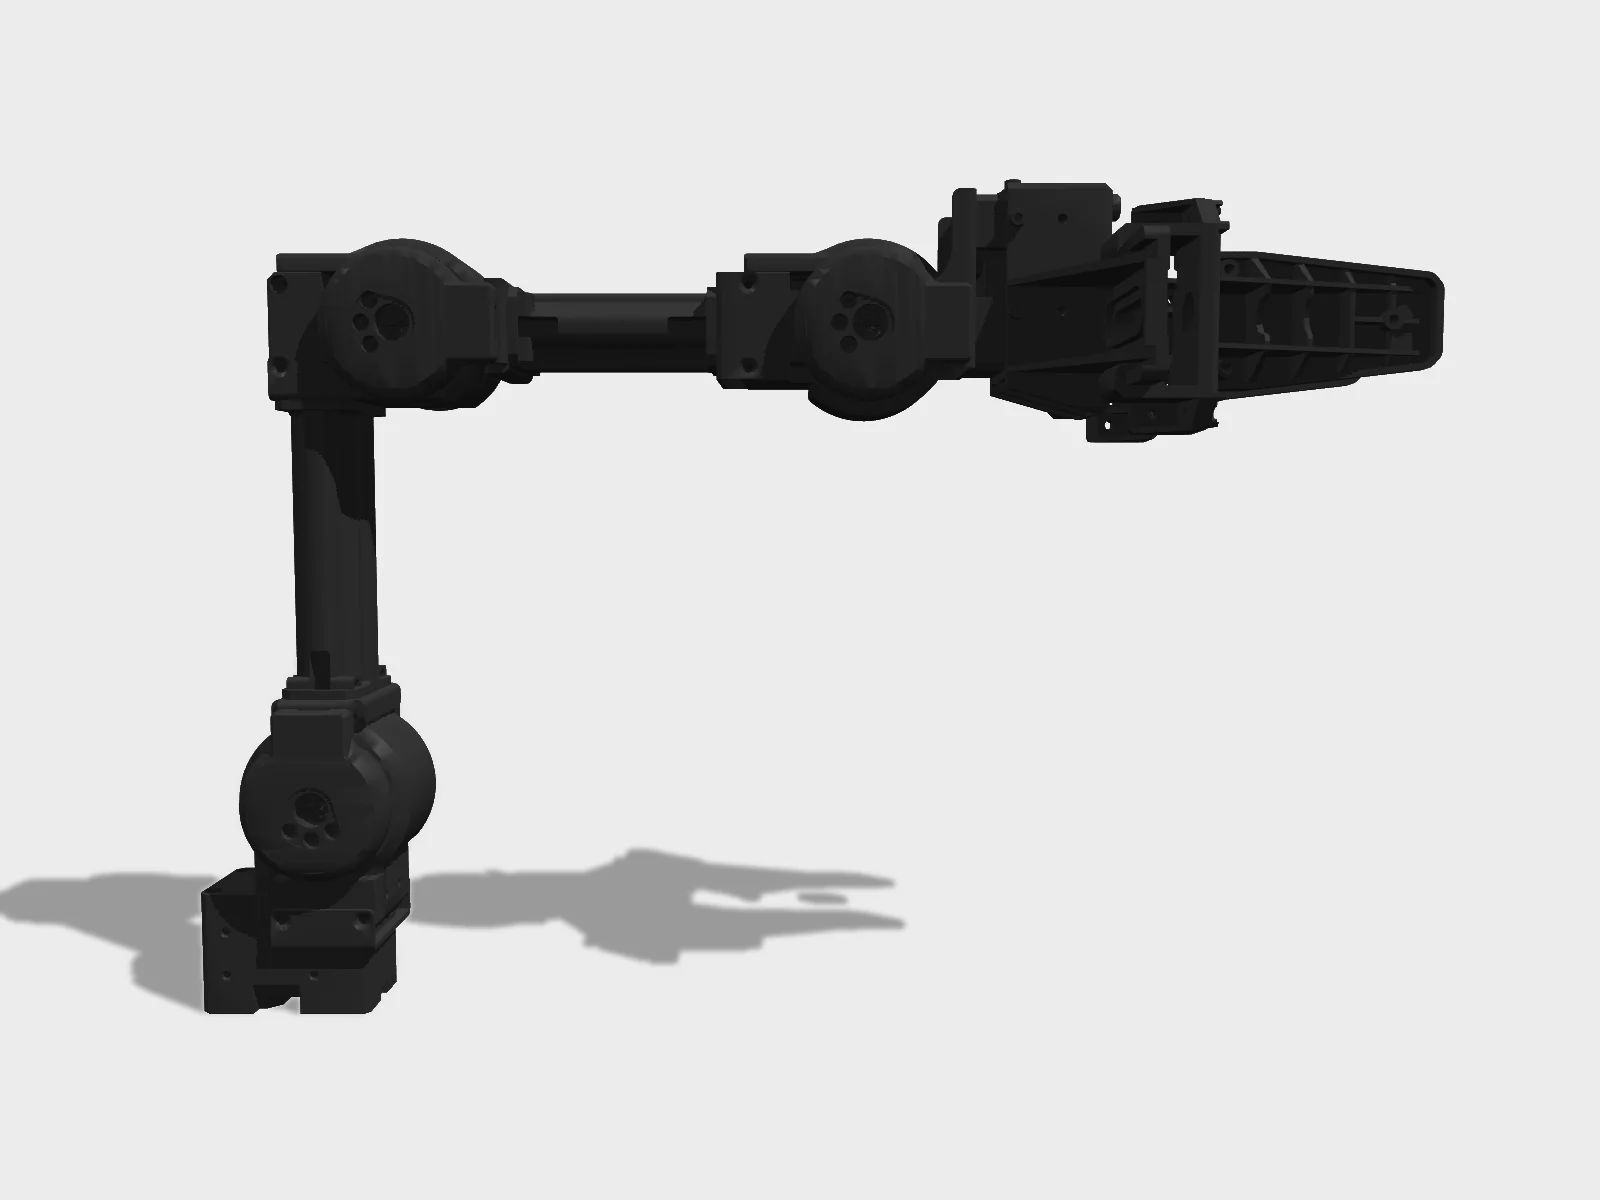
Side view of the same URDF render, the model's zero pose.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source 4 s turntable of the URDF studio render.Rendered by Hyperspawn from ROBOTIS-GIT/open_manipulator (Apache-2.0) · Hyperspawn render · source OpenManipulator 03 : Assembling the OpenManipulatorROBOTIS OpenSourceTeam · official embed · source OpenManipulator 06 : Manipulation with ROSROBOTIS OpenSourceTeam · official embed · source
PARTIAL · Owned units, not builds.
0
Verified builds
0
Labs & spaces
1
Maker HQ
1
Countries
No verified build of OpenMANIPULATOR-X (RM-X52-TNM) on the map yet. The first reviewed build report puts the first bright point here. Report a build.
humanoidrobots.systemsKnow it
humanoidrobot.buildBuild itclosed · Closed hardware. Buy link only.
humanoidrobots.trainingTrain ithumanoidrobots.teamFind its crewpartial · Owners and labs, not builders.humanoidrobots.earthSee it on the mappartial · Owned units, not builds.